METR4810 · team of 4 · 2026
A steered cutter pod for a tunnel-boring robot
steered cutter pod
The machine bored through both end blocks at the final demonstration, but the pod would not steer deep in the bend, so the two passes did not meet; I traced it to an under-torqued steering servo.
- My role
- Steering and navigation lead in a team of 4; I designed the steered cutter pod
- When
- Jul – Oct 2026
- Tools
- Fusion 360, 3D printing
- Files
- Not published
The full write-up
- The problem
- What I did
- Result
- What went wrong
- Credits
The problem
A rig pushes an arm through three foam blocks, and the cutter on the end of the arm has to bore a tunnel that follows a curve, so the head must steer as it advances.
What I did
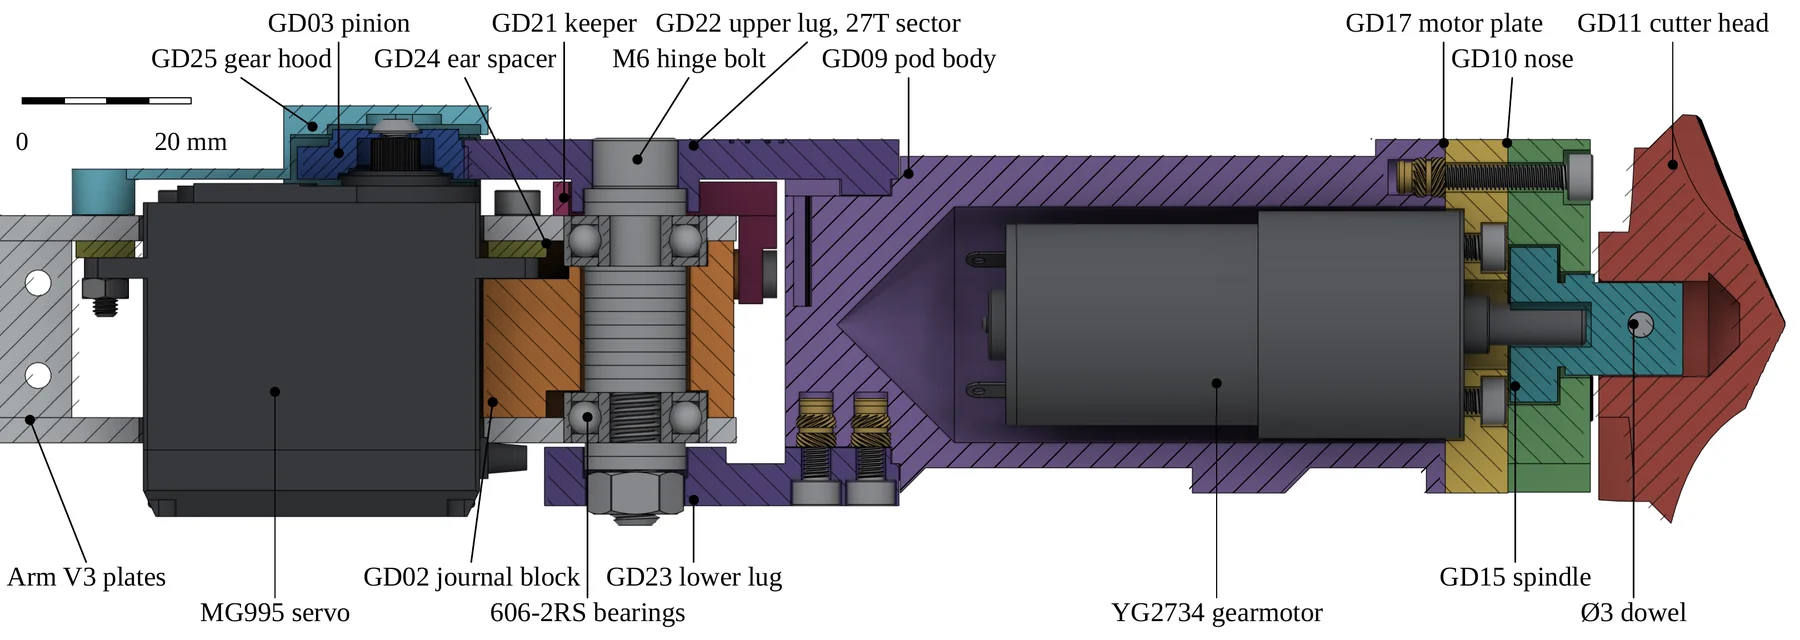
- I replaced the team's first concept, 18 joints along the arm, with a single steered hinge just behind the cutter.
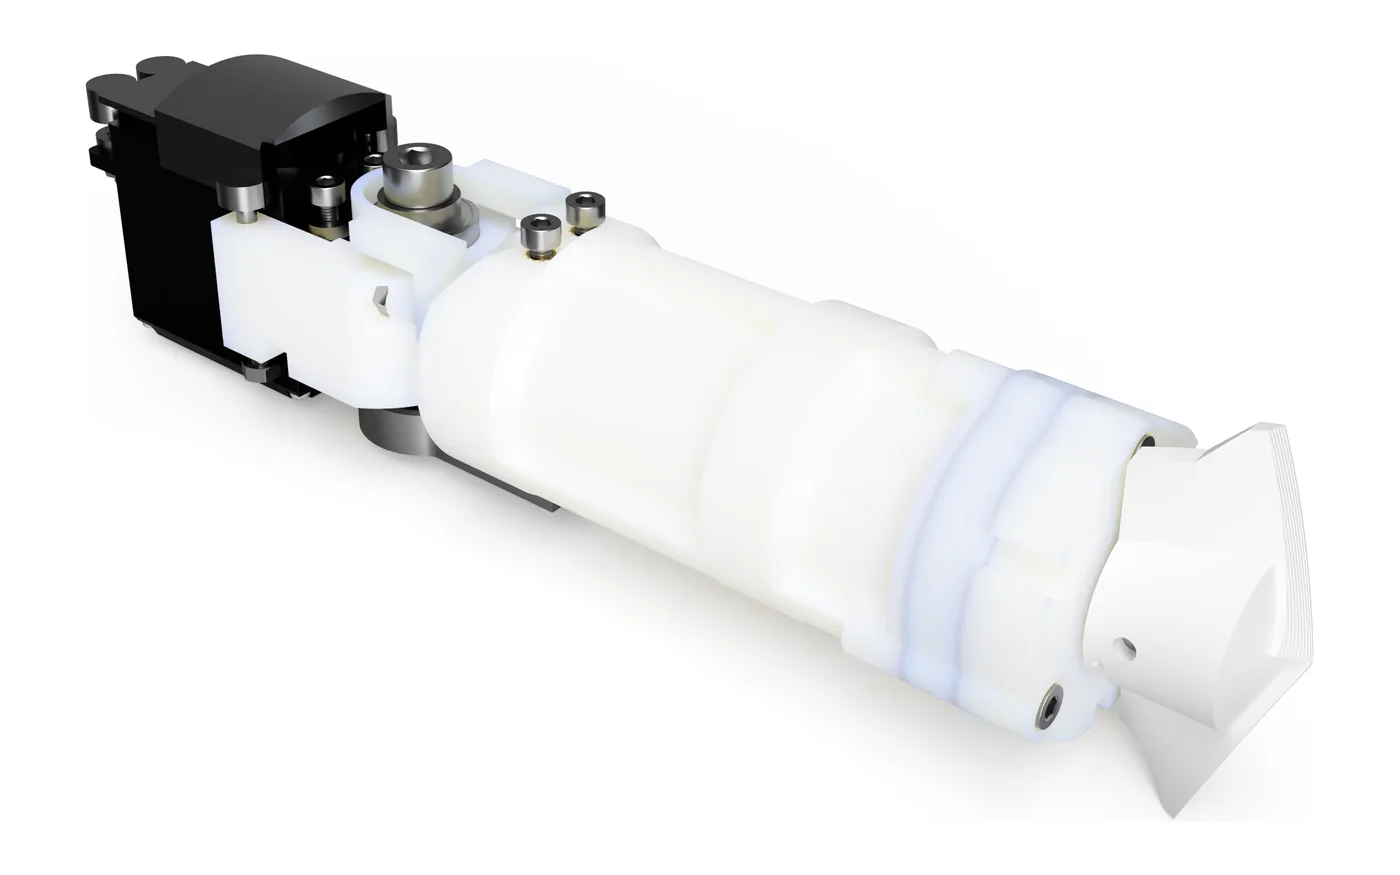
- I designed the hinge, the servo gear drive and the cutter head in Fusion 360.
- I derived the pod's steering schedule from the tunnel's geometry.
- A week-11 redesign of the cutter head cut its mass from 16.0 g to 6.7 g.
Result
- At the final demonstration the machine bored through both end blocks.
- The pod would not steer deep in the bend, so the two passes did not meet.
What went wrong
- Steering torque: my failure analysis traced it to the steering servo, which had too little torque for the side load from cutting.
Credits
METR4810 was a team project at UQ. The rig, the electronics and the base firmware are teammates' work; the page covers the cutter pod I designed.